 Zenbird Editorial Team
ineRobo has completed a field trial combining robotic seeding with volunteer manual harvesting, testing an operational model to support small-scale rice farming.
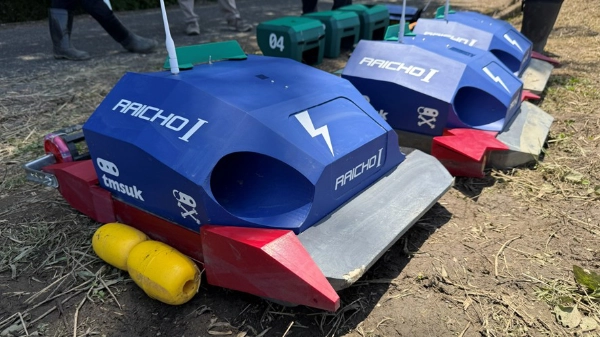
The demonstration took place in a paddy field in Kitakyushu City. For the initial planting on 17 May, robotics company tmsuk deployed its Raicho 1 rice-farming robot to sow the crop. Software developer Unyte also joined the project to test an application that tracks volunteer labour.
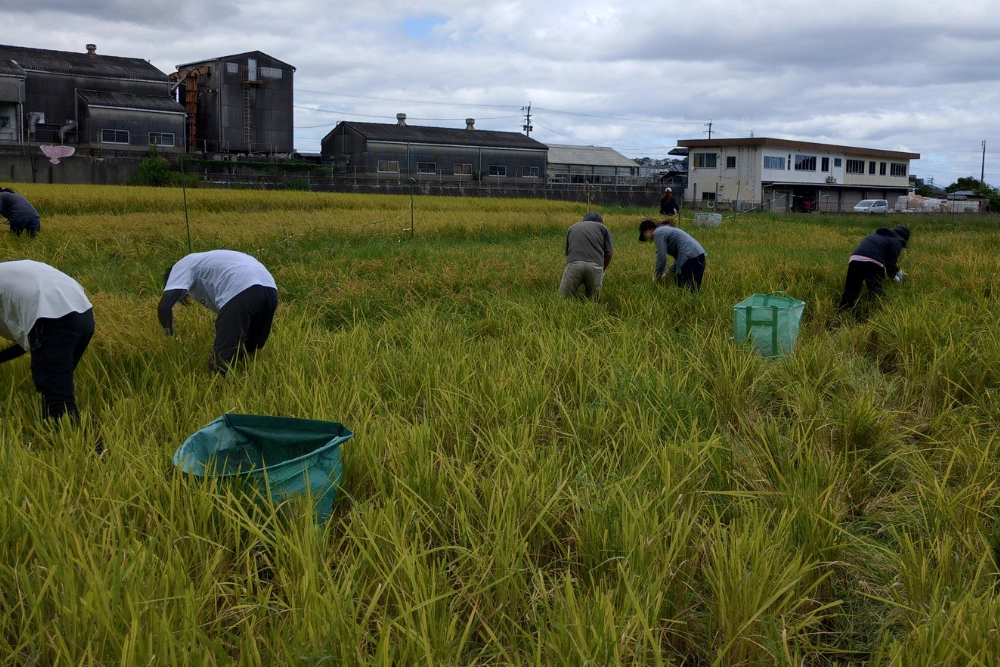
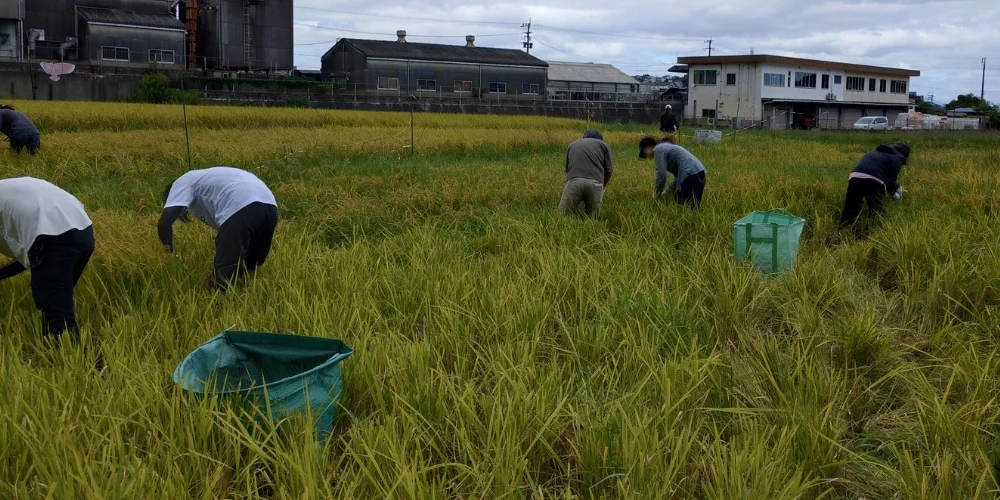
The trials hope to address operational challenges in low-chemical rice cultivation. Because existing agricultural robots cannot reliably distinguish weeds from growing rice stalks, manual labour is still required between rows. Approximately 10 volunteers weeded the plot by hand on 30 August 2026 before installing bird netting. With the crop maturing earlier than scheduled and an automated harvesting robot still in development, volunteers returned to harvest the rice stalks manually on 20 September 2026.
The project is funded by the PwC Foundation under its spring 2026 food systems grant programme. During both the weeding and harvesting events, participants logged their farm tasks and local purchases in the specialised app. ineRobo uses these records to calculate each volunteer’s contribution and distribute a portion of the harvest accordingly.
The harvested crop is scheduled for milling and shipment to test members of Inekatsu, a subscription programme through which supporters back robotic rice production in exchange for regular updates and a share of the yield. Member numbers are nearing the initial ceiling set by crop volume, but ineRobo continues to accept applicants while preparing further field tests.